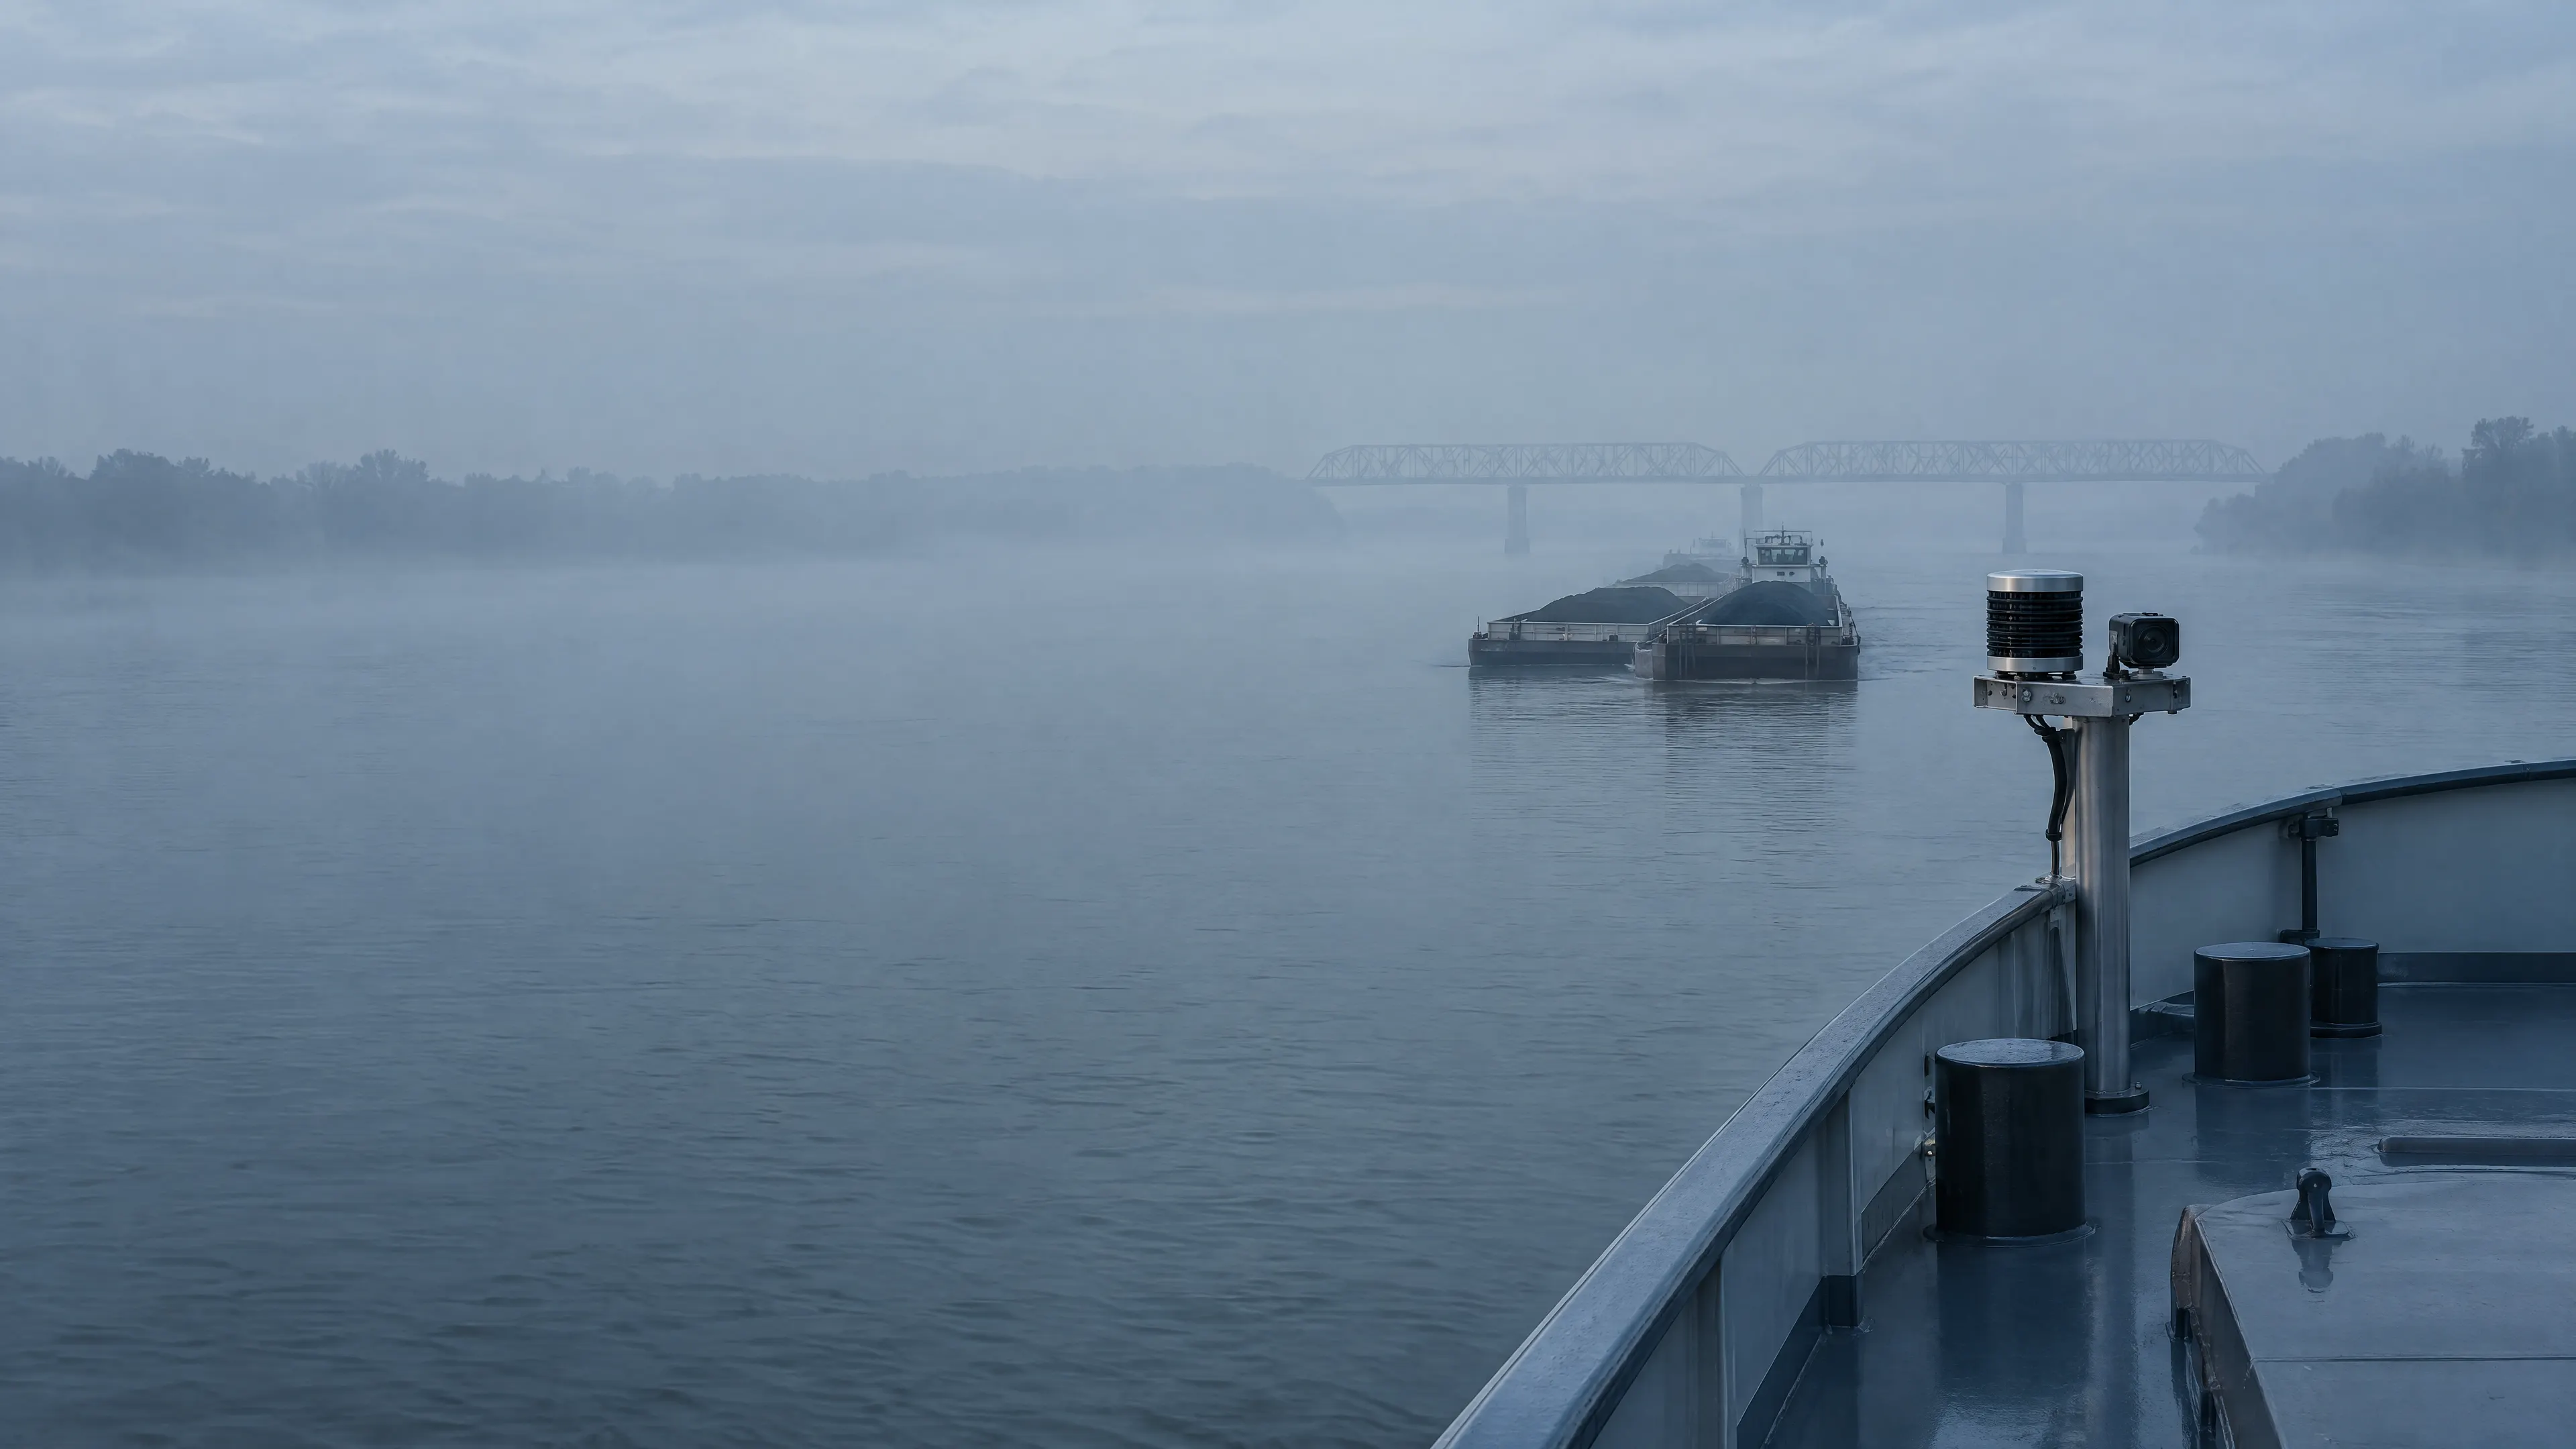
85-Class Vision and Fusion on a 105 m Vessel
Dr.-Ing. Ahmad Goudah is a Computer Vision and Perception Engineer building YOLOv8, LiDAR, DGPS, and AIS fusion for autonomous vessels and vehicles.
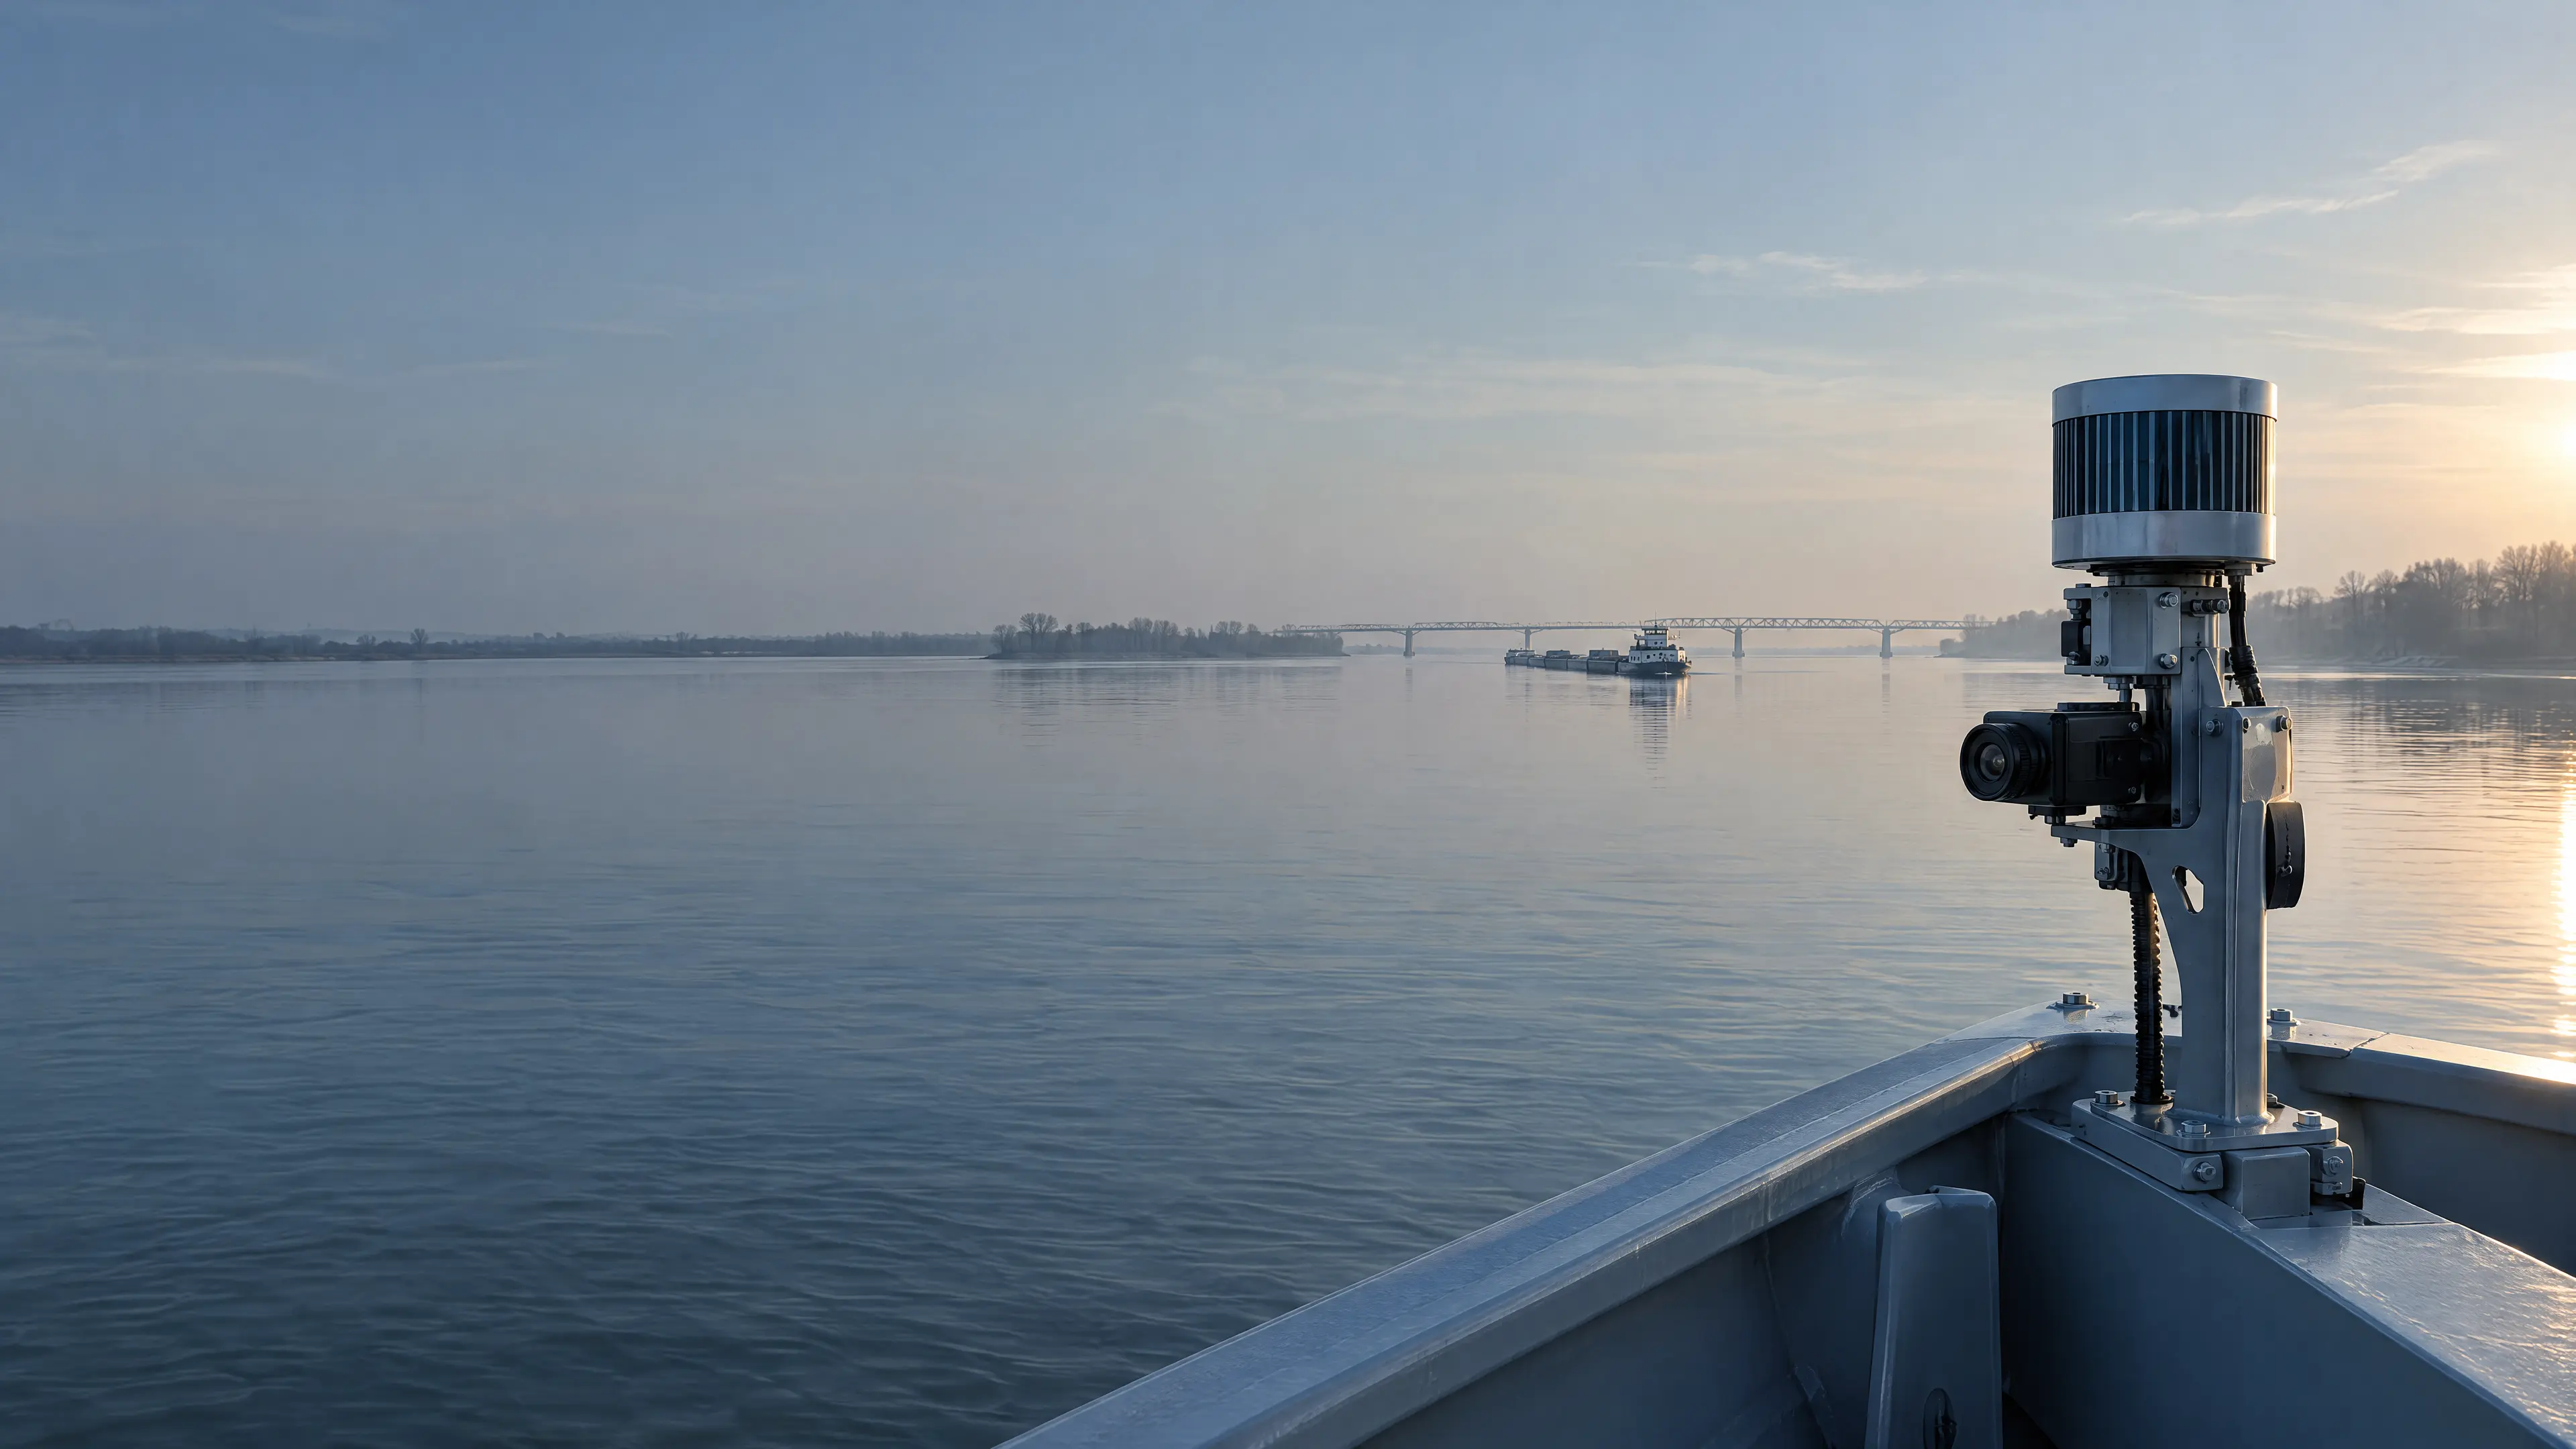
Generated river photograph (not Niedersachsen 22); the sensor and target overlays are illustrative.
Niedersachsen 22 Sensor Layout and Fusion Subset
Niedersachsen 22 (105 m) mounts bow, mast, side, and stern sensors. The thesis fuses six Basler acA4096-11gc cameras, Velodyne VLP-16 and Ouster OS2-64 LiDARs, Trimble BX992 GNSS, and AIS; bow stereo and mast radar remain unfused.
- Camera (Rear View) - Basler acA4096-11gc mono camera
- Lidar (Short Range) - Velodyne VLP-16 3D LiDAR
- Camera Bb (Forward view) - Basler acA4096-11gc port
- Camera Stb (Forward view) - Basler acA4096-11gc starboard
- Camera Bb (Rear view) - Basler acA4096-11gc port
- Camera Stb (Rear view) - Basler acA4096-11gc starboard
- Trimble GNSS Antennas - Trimble BX992 dual RTK DGPS
- Stereo camera (a: Bb / b: Stb) at bow
- Lidar (Long Range) - Ouster OS2-64 3D LiDAR
- Camera Bug (Front View) - Basler acA4096-11gc bow
- Radar (on Mast) - foremast navigation radar
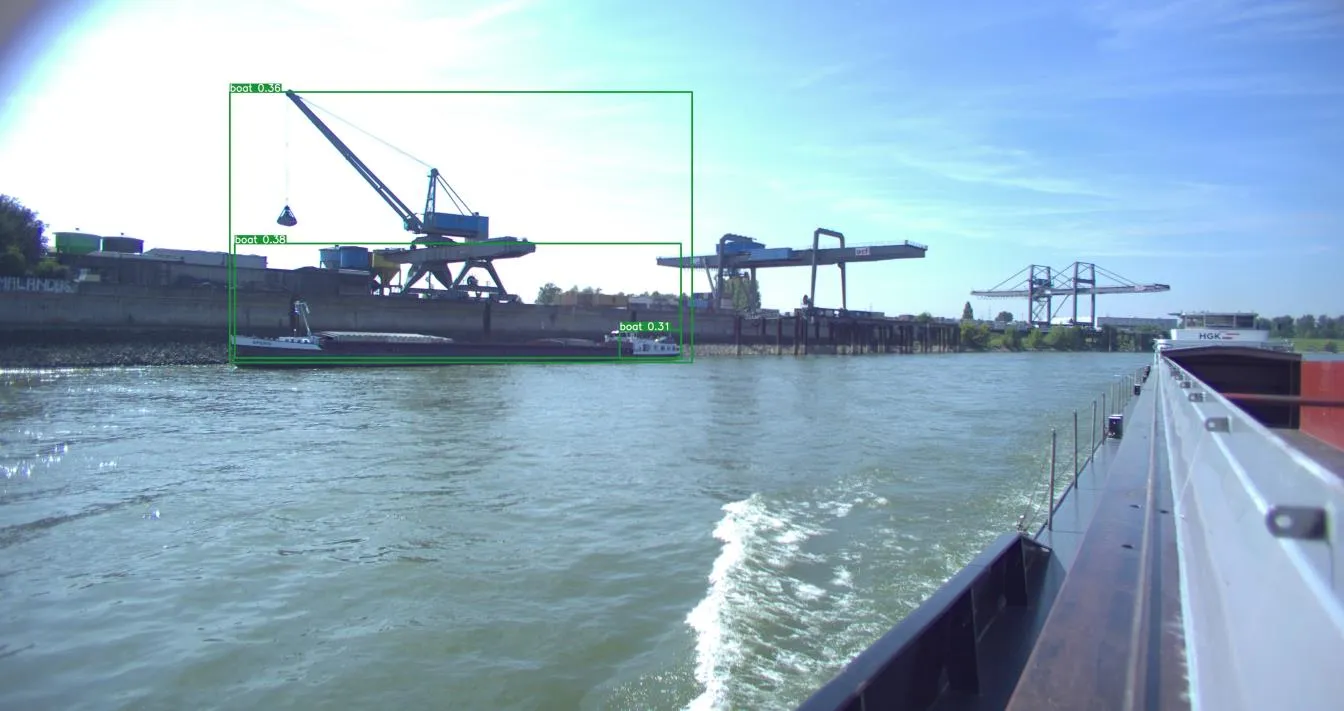
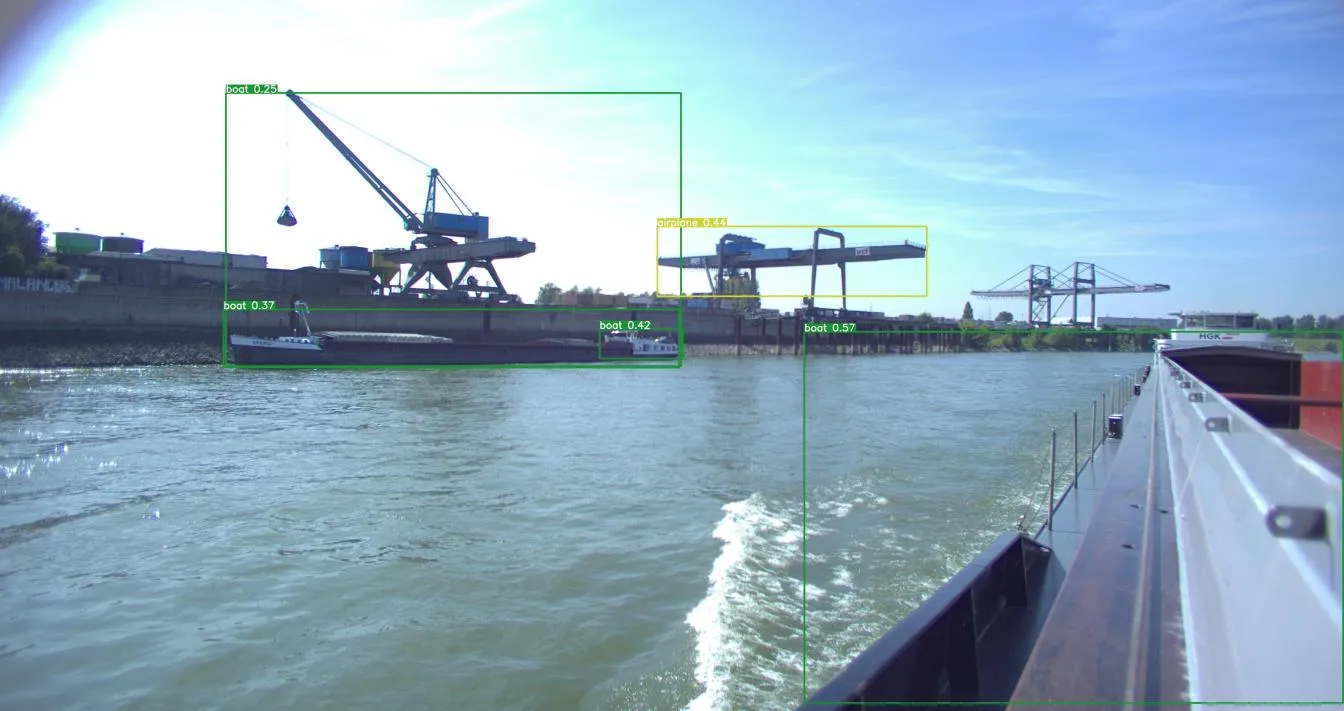
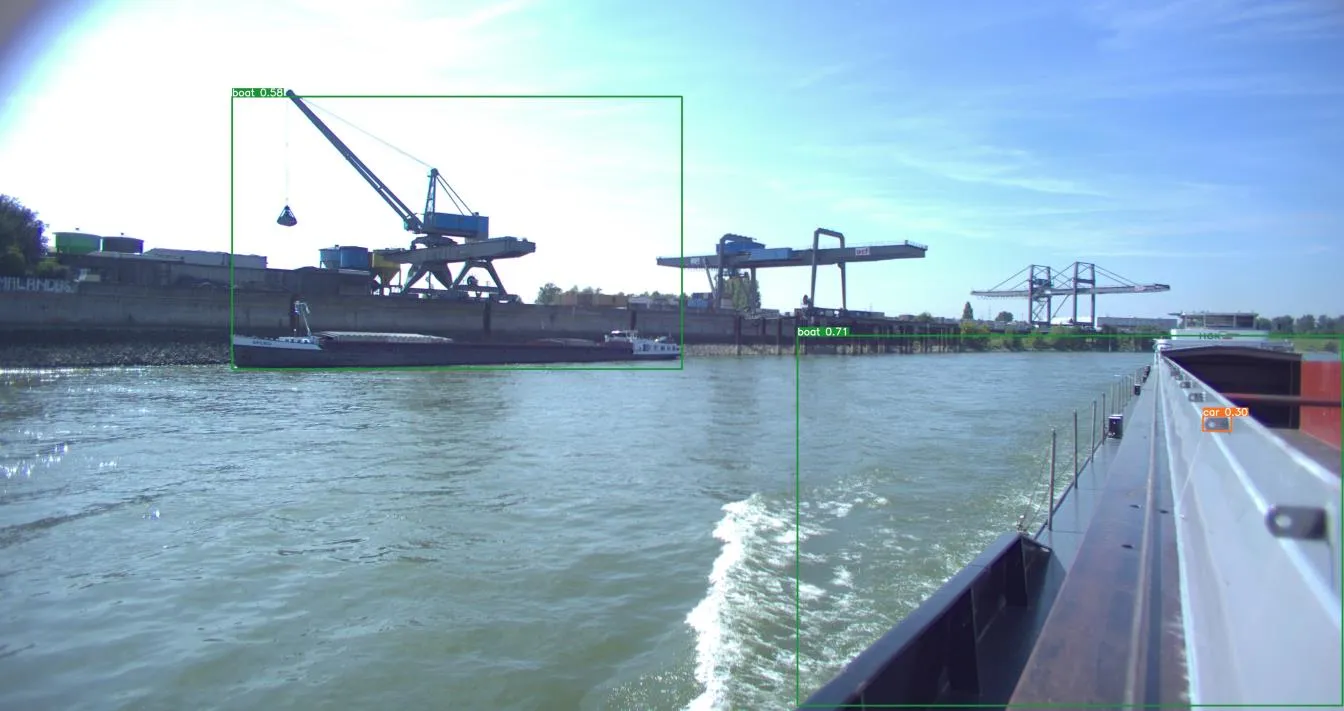
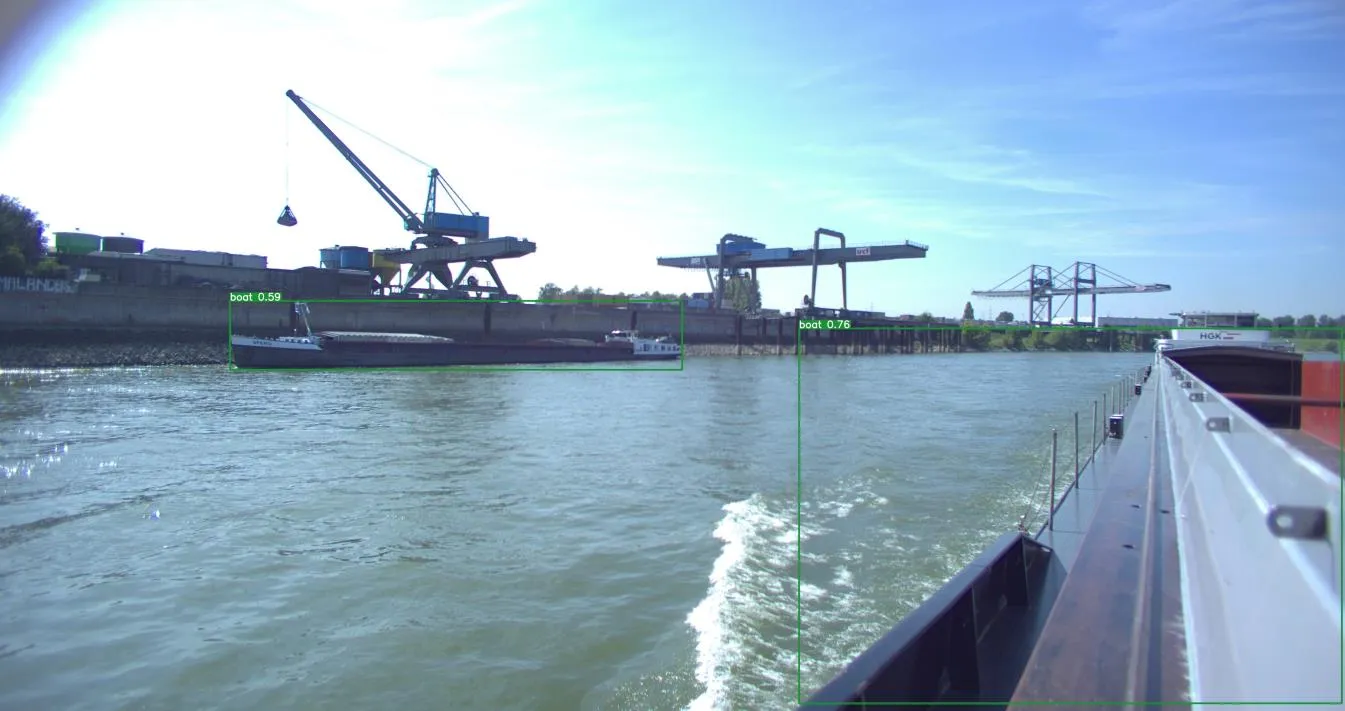
YOLOv5 and YOLOv8x Benchmark on 33 River Scenes
Pretrained 80-class COCO detectors (YOLOv5s through YOLOv8x) were benchmarked on 33 waterway and traffic scenes. Smaller weights merged shore cranes with barges or mislabeled cranes as airplanes, motivating a custom 85-class YOLOv8x detector (3.3 ms on A100).
Camera-LiDAR Object Matching and Web Fusion
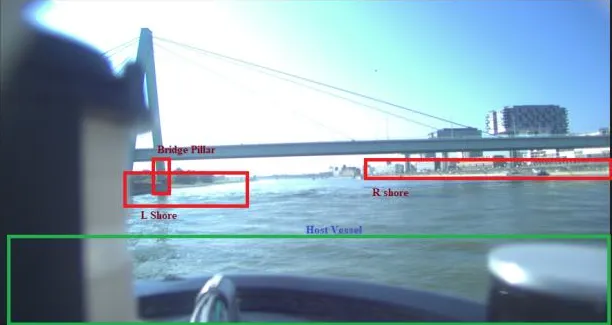
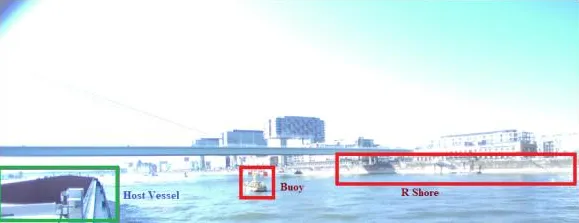
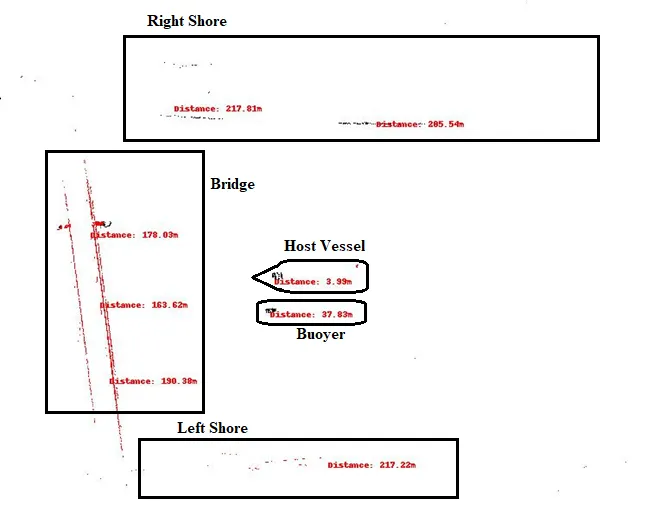
LiDAR point clouds (.ply) are projected into top-down images and clustered with eight-centroid K-Means to compute Euclidean distance in meters for waterway objects labeled in synchronized shipboard camera frames.
Six-Camera and GPS Fusion Monitor
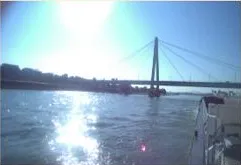
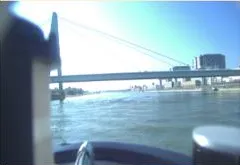
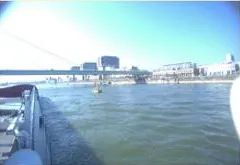
The web monitoring program synchronizes six shipboard Basler camera streams around a central stitched panorama, logging folder source, millisecond frame interval, GPS timestamp, and latitude and longitude coordinates.
- Folder
- 20210908_1
- Interval
- 2000 ms
- Frame
- 2
- Date
- 08\09\2021
- Time
- 10:17:22.798
- Latitude
- 50.9331483333333 N
- Longitude
- 6.96744666666667 E
 Back Left Side
 Front Camera
 Back Right Side
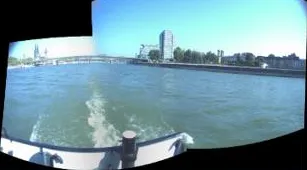 Stitched Image
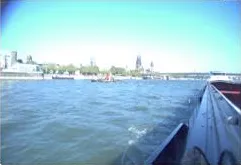 Front Right Side
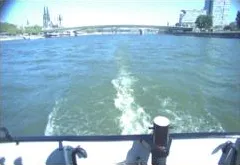 Back Camera
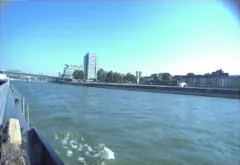 Front Left Side
Career Log: Alexandria to Duisburg (2001-2025)
- 2001 - 2006
B.Sc. in Computer Engineering / Computer Science
Arab Academy for Science, Technology and Maritime Transport (AASTMT)
Alexandria, Egypt
Graduated Very Good (GPA 3.1/4.0) with a thesis on hardware and software implementation of AVR microcontroller-based VoIP systems.
- 2005 - 2009
Software & Web Developer
Toyota Abdul Latif Jameel Co., Noortech Co., and Al-Amal
Jeddah, Saudi Arabia & Alexandria, Egypt
Built customer archiving and cheque systems at Toyota ALJ, access control and attendance systems at Noortech, and AVR LED displays at startup Al-Amal.
- 2010 - 2013
M.Sc. in Computer Engineering / Computer Science
Arab Academy for Science, Technology and Maritime Transport (AASTMT)
Alexandria, Egypt
Graduated with Distinction / Excellent (GPA 3.4/4.0); thesis on algorithms and applications for smart-grid three-phase automatic load balancing using genetic algorithms.
- 2009 - Present
Data Scientist, Team Leader, System / Web Developer & Lecturer
Arab Academy for Science, Technology and Maritime Transport (AASTMT) & Alexandria University
Alexandria, Egypt
Led university admission, payroll, elections, KPI dashboard, and scientific publishing (apc.aast.edu) platforms while teaching AI, pattern recognition, big data, and embedded systems.
- 2019 - 2025
Doctoral Researcher (Dr.-Ing., cum laude)
University of Duisburg-Essen, Chair of Mechatronics
Duisburg, Germany
Built 85-class YOLOv8x detection, 3D LiDAR K-Means ranging, and Camera-LiDAR-DGPS-AIS fusion on the 105 m vessel Niedersachsen 22.
Dissertation and Peer-Reviewed Publications
Doctoral dissertation and five papers spanning YOLOv8 inland vessel object detection, power consumption prediction, and genetic-algorithm smart-grid load balancing.
- 2025
Real-time Detection Models for Surrounded Environmental Objects in Highly Automated Vehicles and Inland Vessels
- 2023
- 2022
- 2020
- 2019
Smart Load Balancing in Smart Grids Using Genetic Algorithms
- 2016
Three-Phase Automatic Load Balancing for Single Phase Loads in Smart Grids using Genetic Algorithms
Contact Dr.-Ing. Ahmad Goudah in Dortmund
Based in Dortmund, Germany, bringing 6 years of doctoral perception research and 15+ years of software engineering to shipped products. Reachable by email, WhatsApp (+49 178 3606461), or LinkedIn.